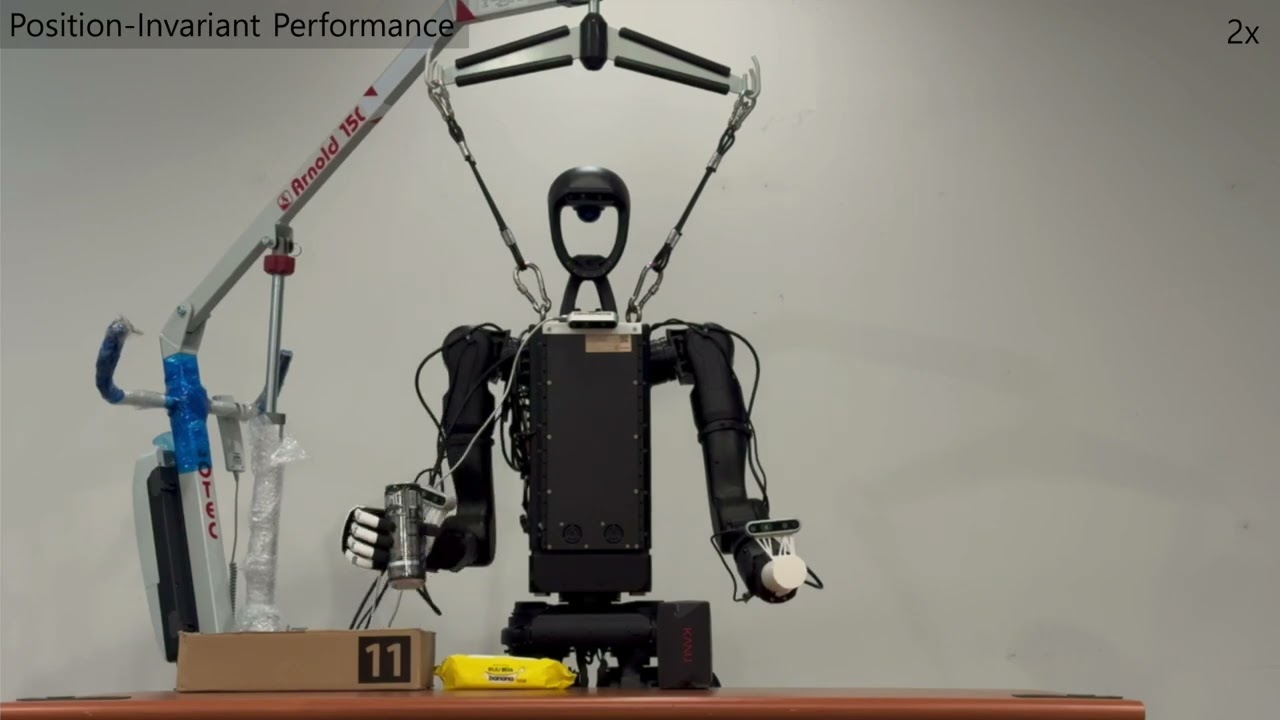
 Watch experiment ↗01
Locomotion and loco-manipulation
Humanoid Control
- Locomotion
- Whole-body motion
- Physical AI
OPEN POSITIONSRCI Lab is recruiting motivated undergraduate researchers and graduate students.
Recruitment details →ROBOT CONTROL · PHYSICAL AI · INTELLIGENCE
We build control and intelligence that help robots move, collaborate, and make decisions in complex, human-centered environments.
WHAT WE DO
From optimal control to Physical AI, our work connects rigorous methods with experiments on real robotic systems.
Watch experiment ↗01Locomotion and loco-manipulation
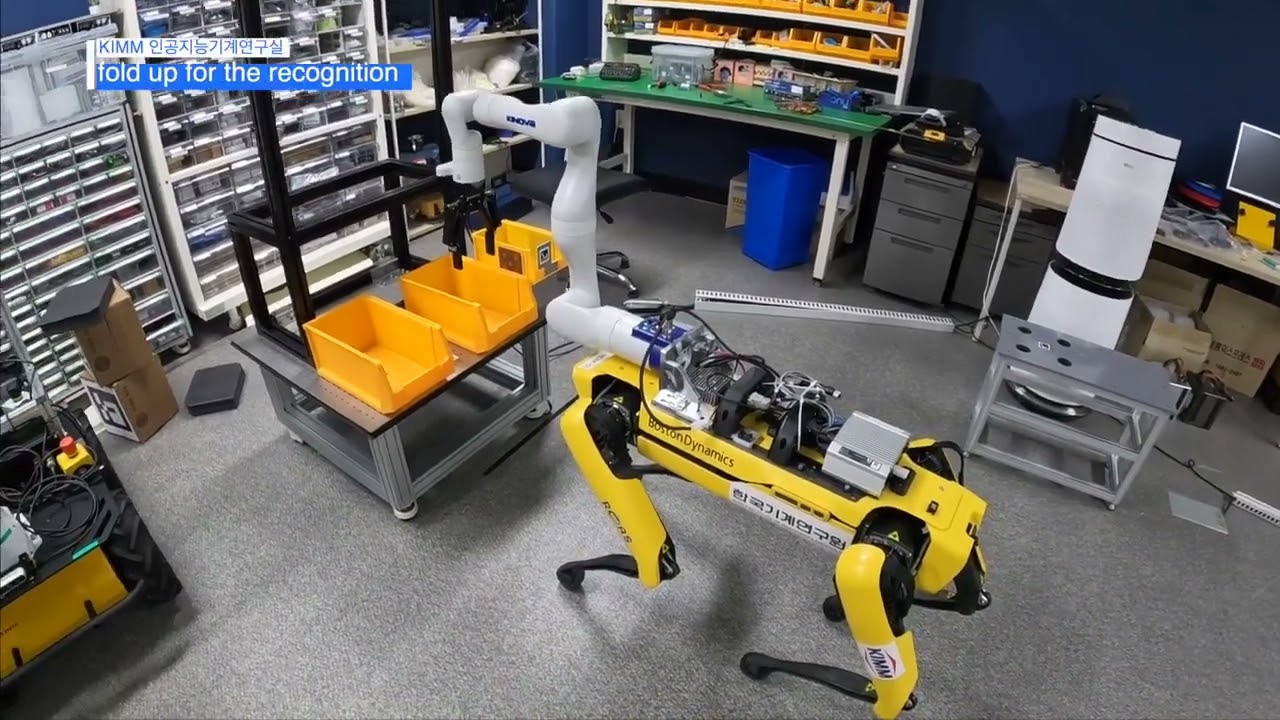 Watch experiment ↗02
Dynamic coordination for complex robots
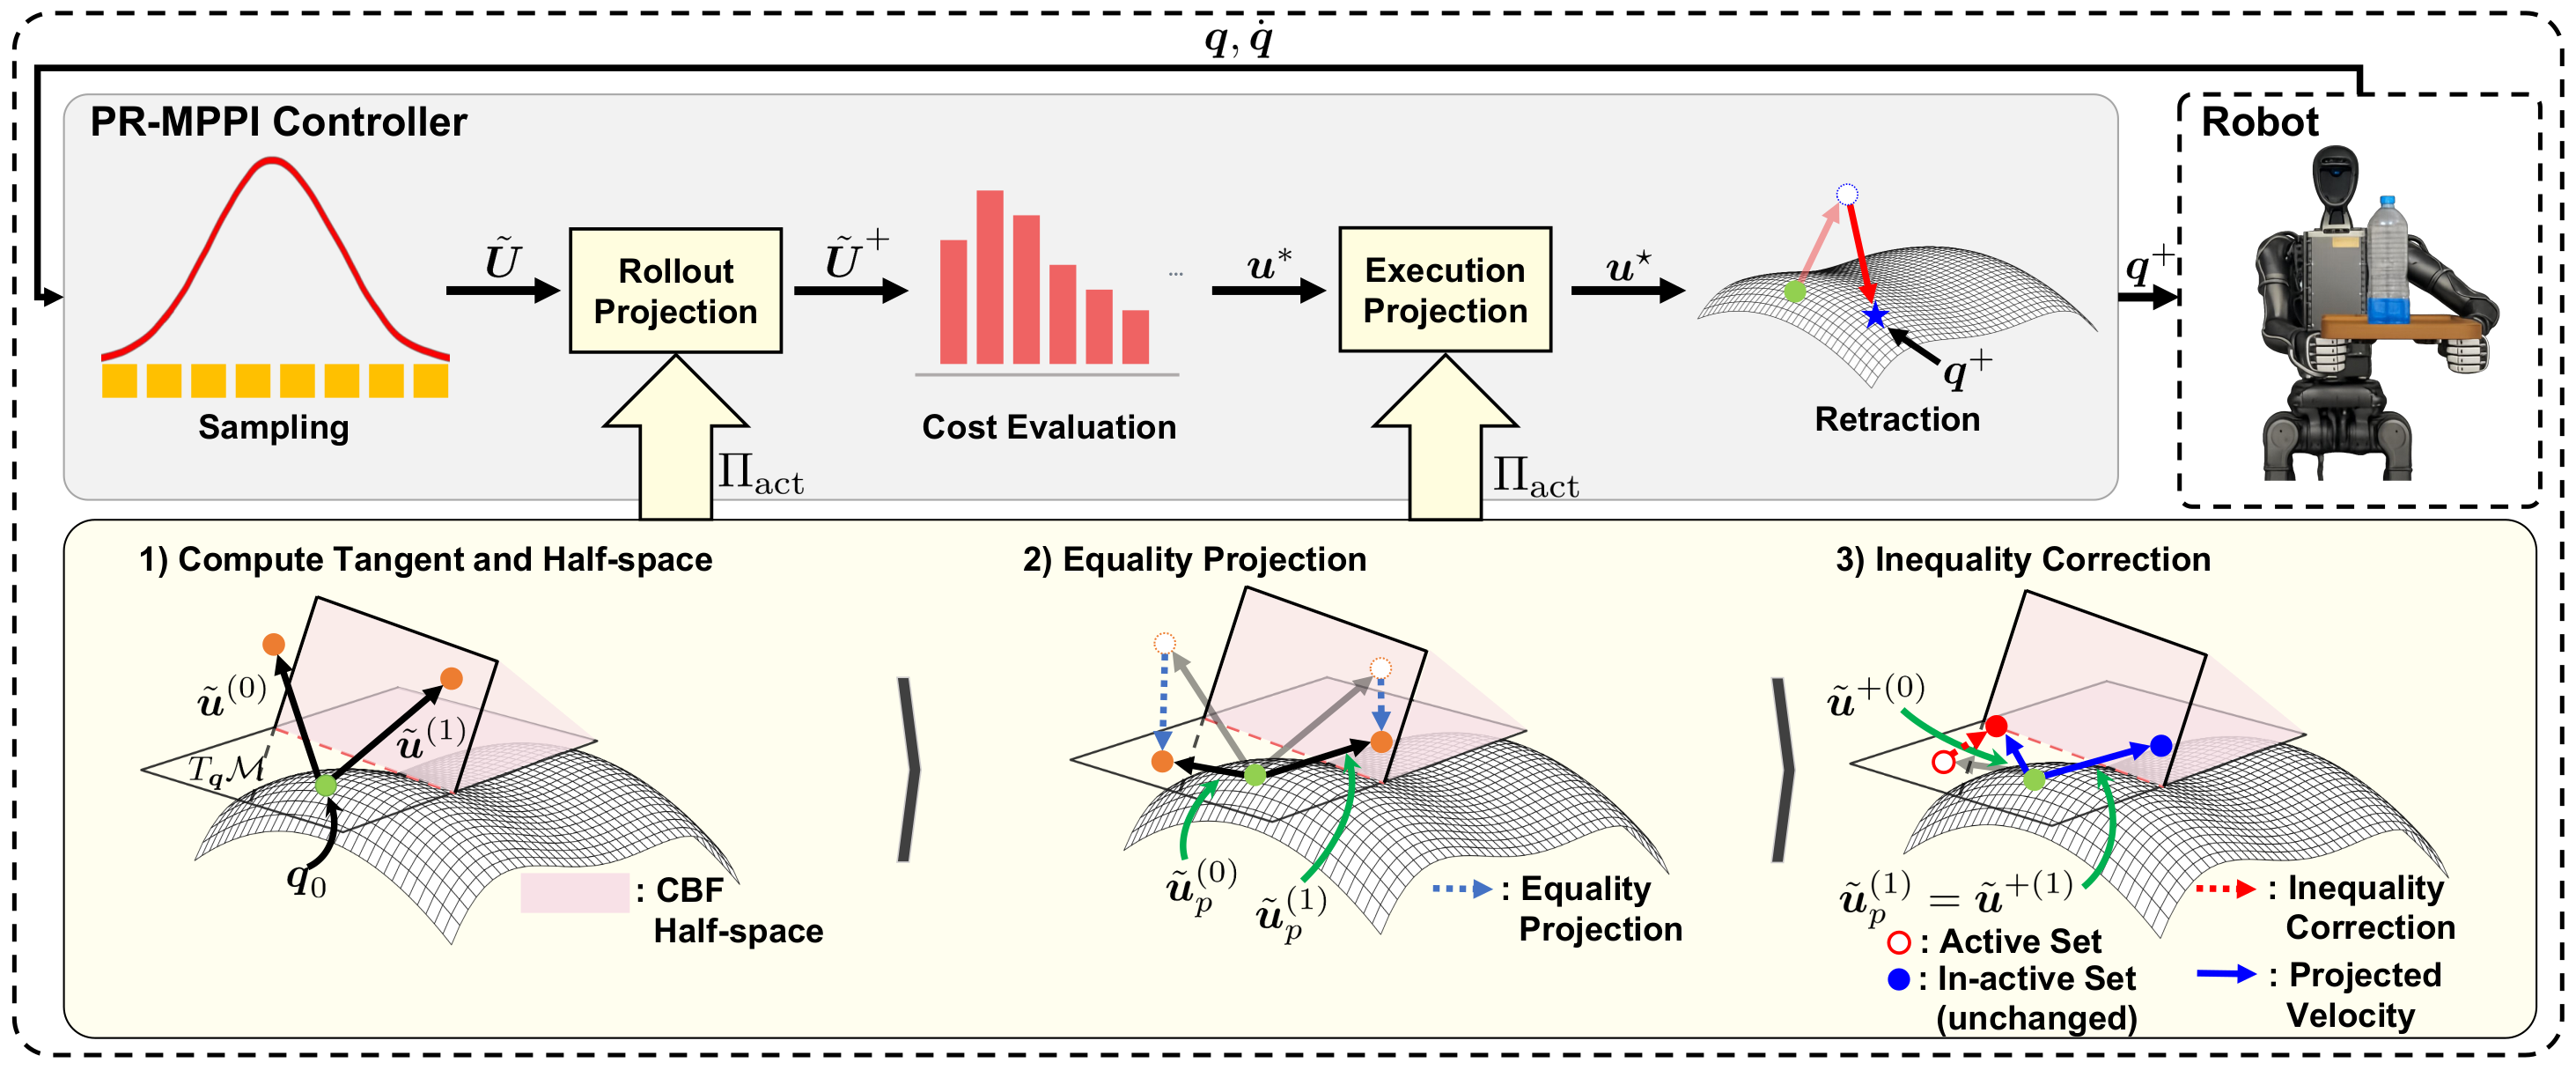 Watch experiment ↗03
Real-time decisions under constraints
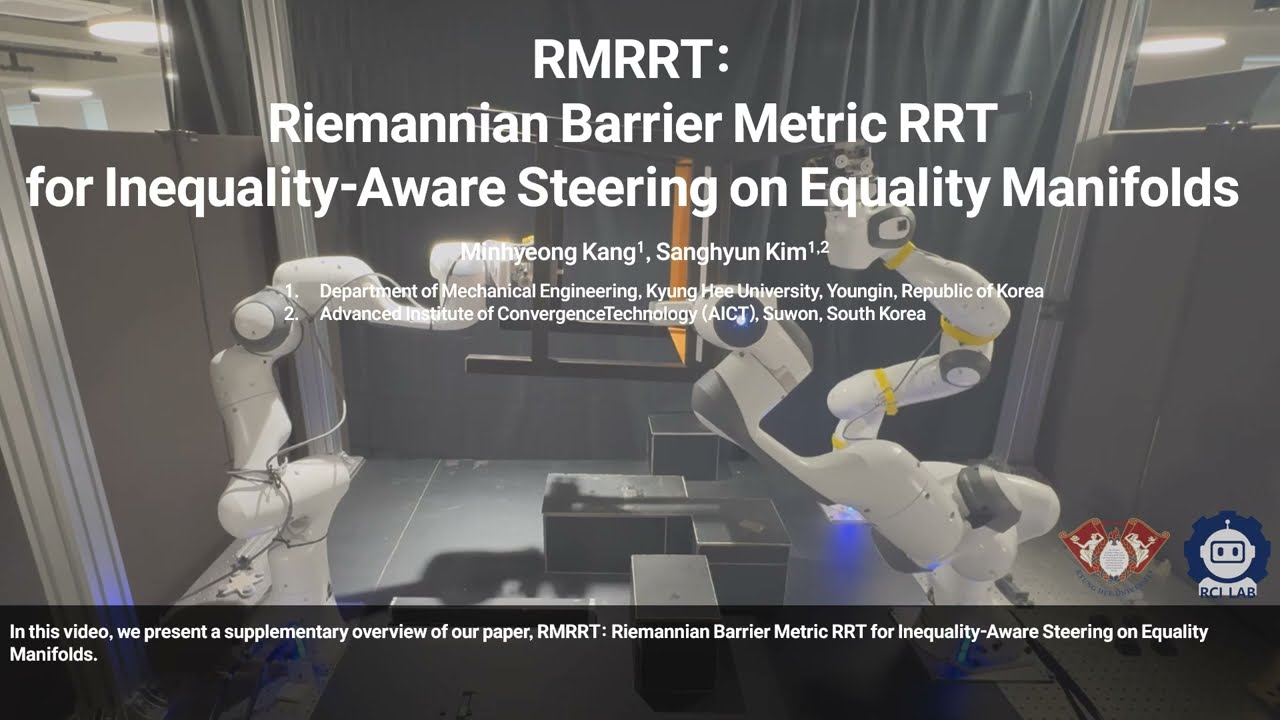 Watch experiment ↗04
Planning on complex constraint manifolds
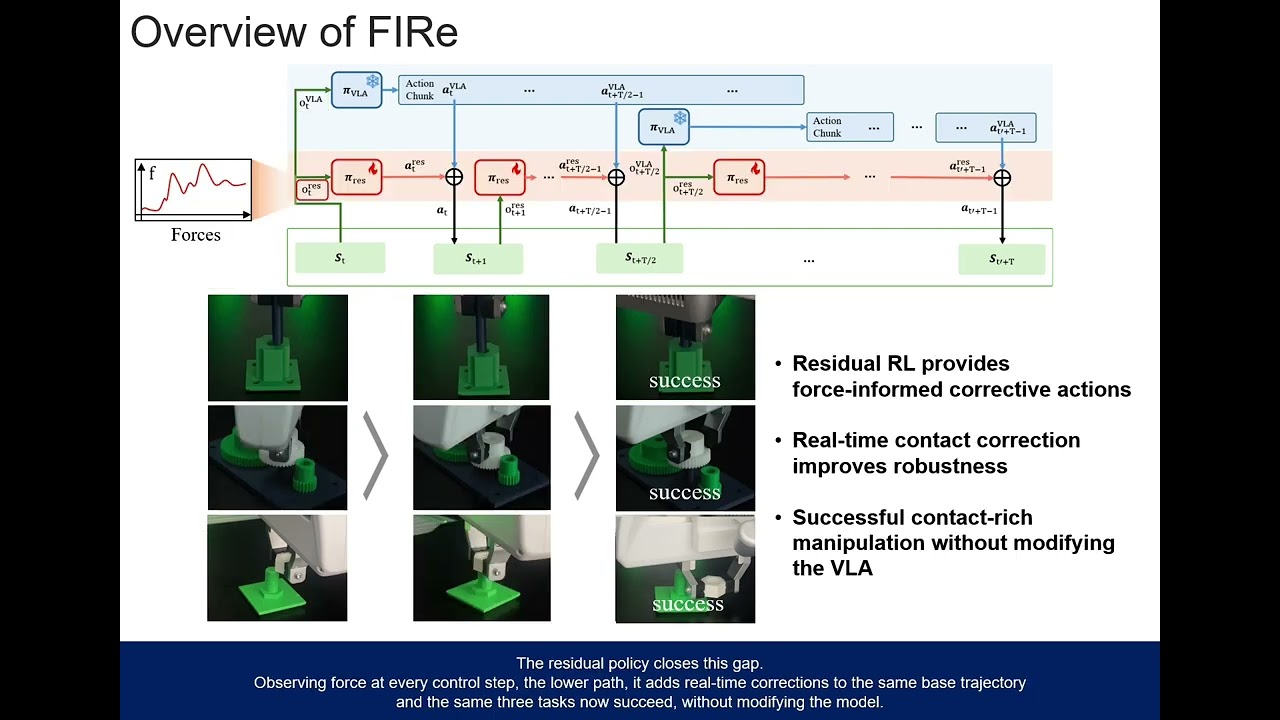 Watch experiment ↗05
Language-guided robot behavior
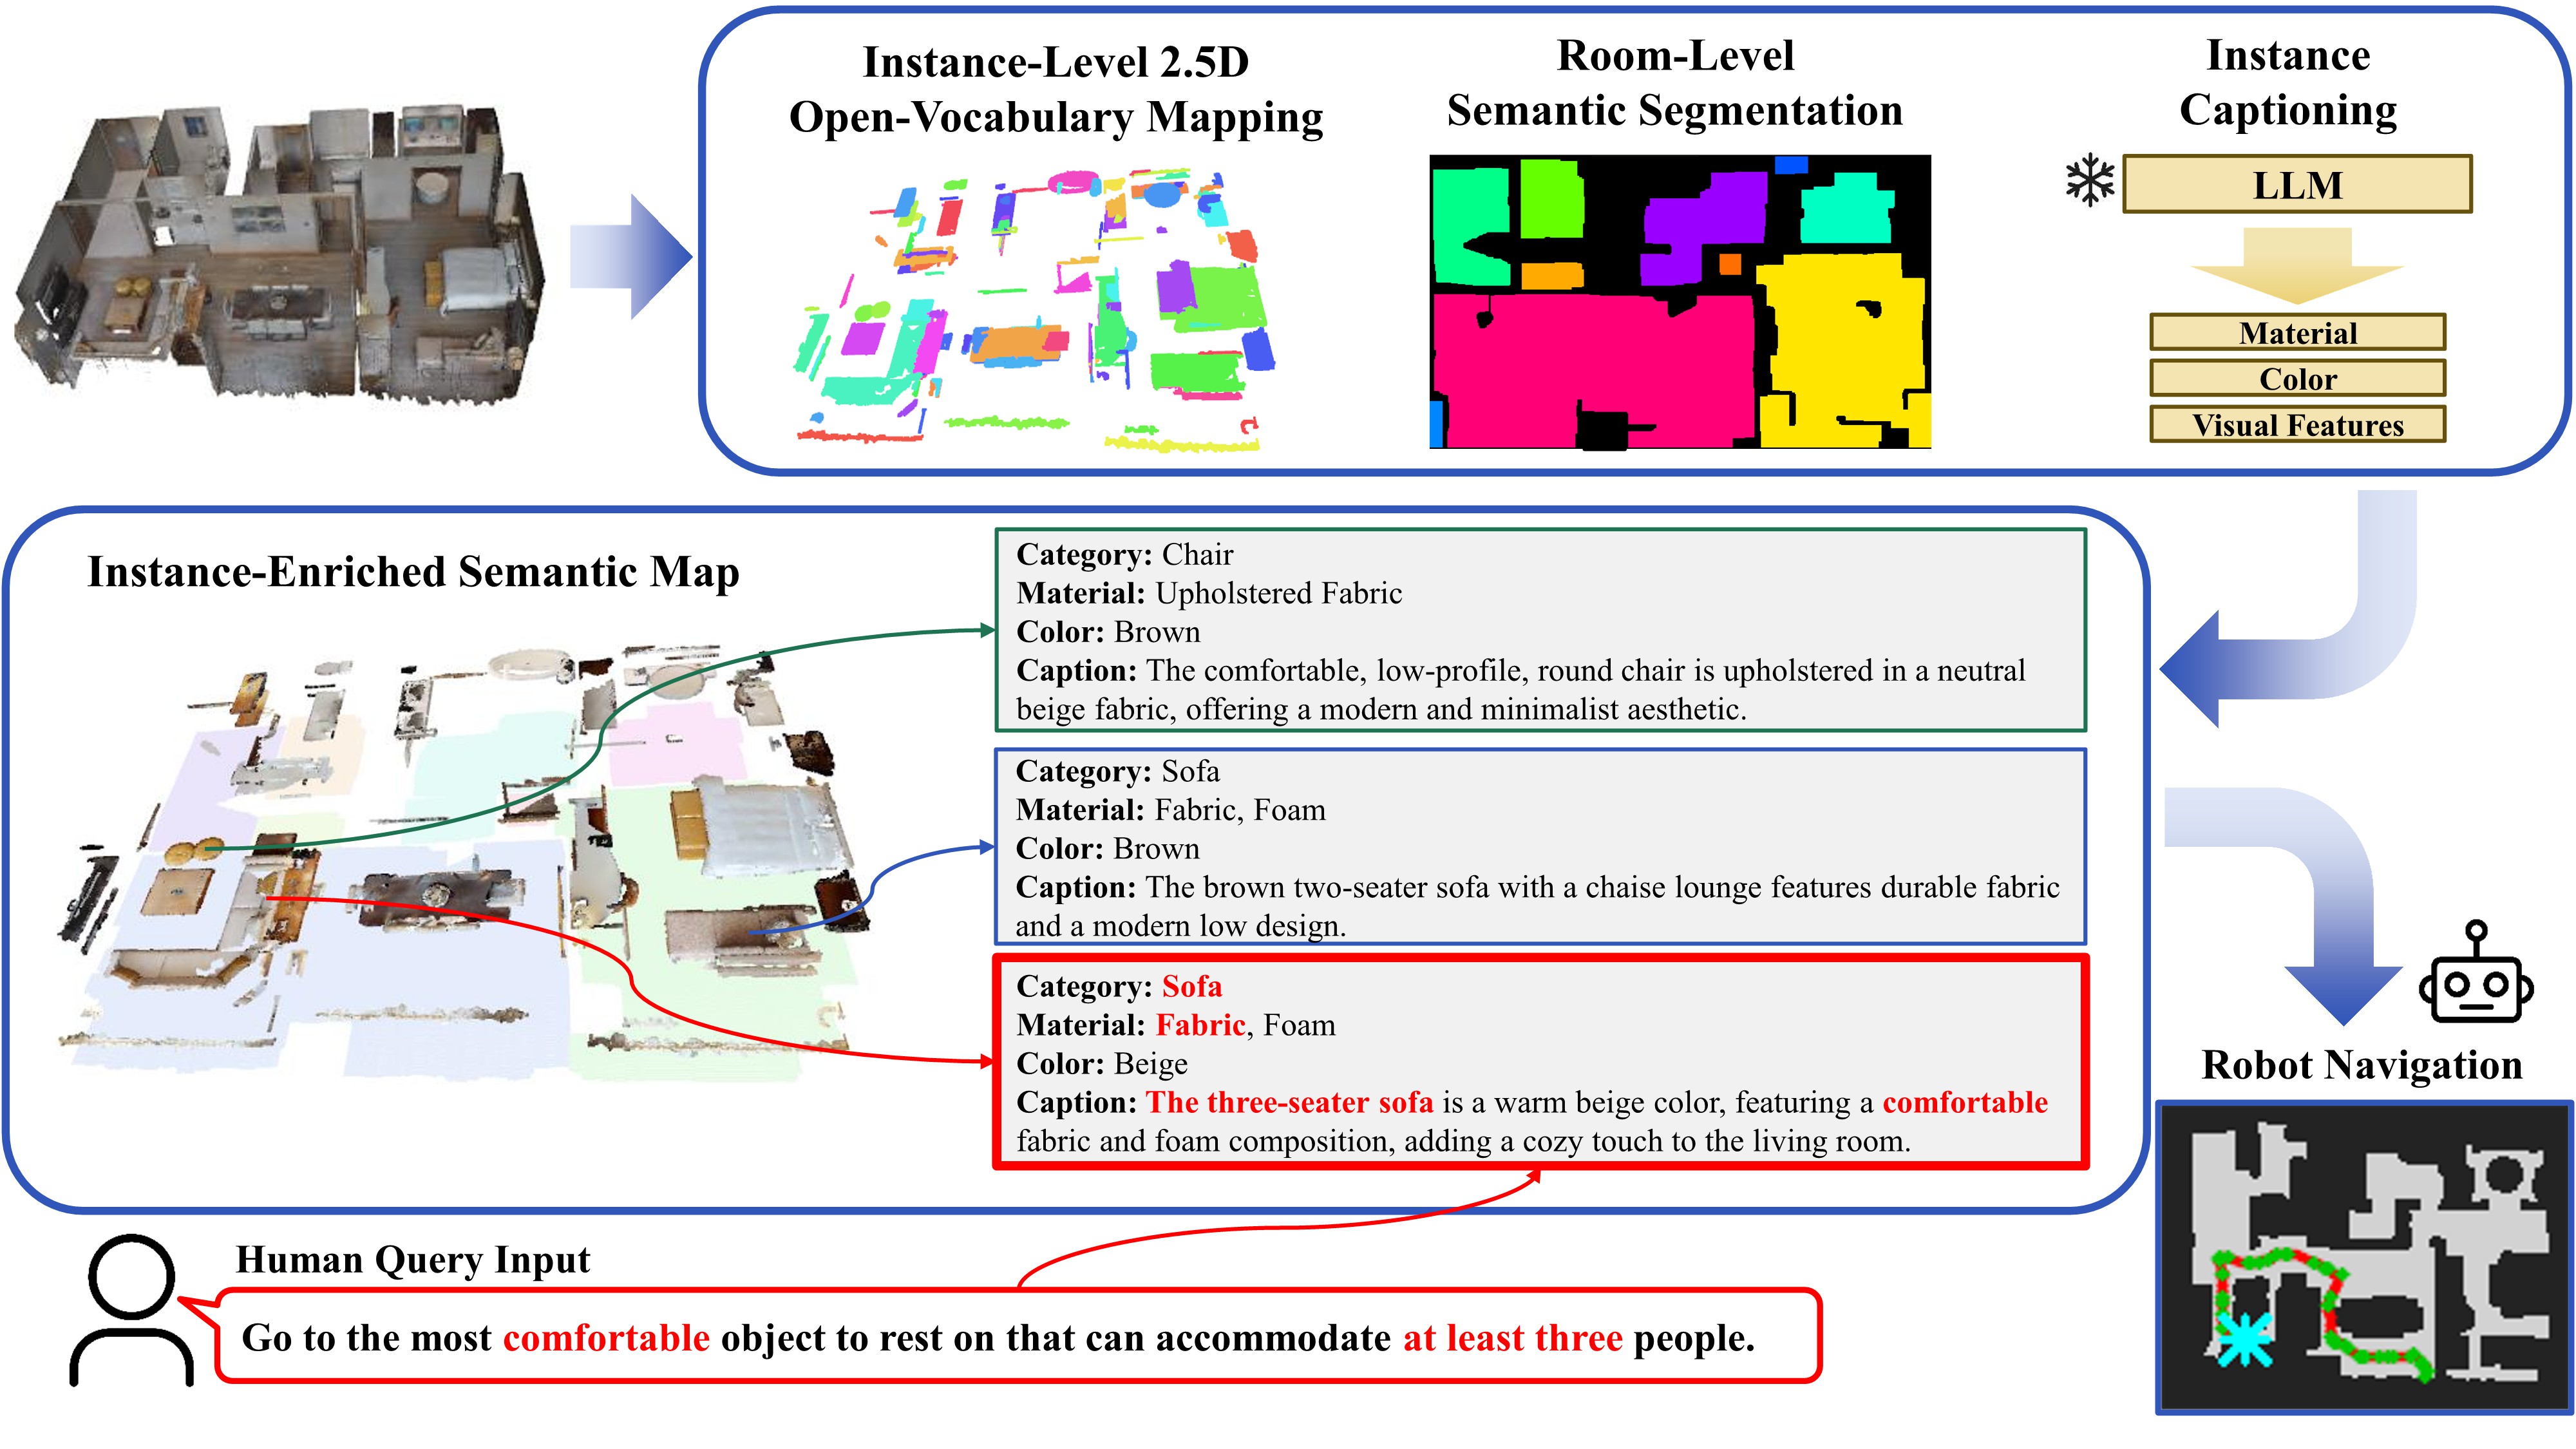 06
Semantic maps for embodied navigation
SELECTED WORK
Research across robot control, motion planning, navigation, and learning-enabled robotic systems.
Browse publications →LAB UPDATES
Leesai Park*, Jiho Hong*, Sanghyun Kim†, “GRACE: Gradient-Free Robot Action Generation via Combined Diffusion-MPPI Posterior Mean Estimation,” IEEE Robotics and Automation Letters, 2026.
과제명: 접촉 작업 자율화를 위한 힘 센싱 휴머노이드 상체 및 접촉 인지 모방학습 기술 · 과제형태: G-대학 창의적 자산 실용화 지원(BRIDGE) 사업 – Advanced Grant(기술이전형) · 지원기관: 경희대학교 · 수행기간: 2026–2027
Minhyeong Kang, Sanghyun Kim†, “RMRRT: Riemannian Barrier Metric RRT for Inequality-Aware Steering on Equality Manifolds,” IEEE Transactions on Robotics, 2026.
과제명: 시뮬레이션 상 AGV(QD·SD 타입) 자율주행 환경 구축 및 SLAM·주행계획 개발 · 과제형태: 산학협력 · 지원기관: 원익로보틱스 · 수행기간: 2026
Dongjo Kim, Minhyeong Kang, Hojin Lee, Nakyoung Lee, Stephen Baek, Sanghyun Kim†, Sanga Lee†, Jeongsu Lee†, “Task-Specific Acceleration-Domain Trajectory Optimization for Smooth and Energy-Efficient Industrial Manipulator Motion,” Engineering Science and Technology, an International Journal, 2026.
과제명: URDF 물리 파라미터 추정·보정 알고리즘 분석 및 프로토타입 적용·검증 · 과제형태: 산학협력 · 지원기관: 코난테크놀로지 · 수행기간: 2026
RCI Lab이 드라마 「연애박사」의 자문에 참여했으며, 연구실의 여러 로봇이 작품에 출연합니다. 자문 참여: 김상현 교수, 강민형·박수환·박다움·조현호. 엔딩 크레딧은 Pictures에서 확인할 수 있습니다.
김상현, 박보형, 조현호, “화학 실험 자율 수행 장치 및 방법,” 대한민국 특허 등록 · 등록번호: 10-3033149 · 출원일: 2026.02.09 · 출원인: 경희대학교 산학협력단.
Seulchan Lee, Sanghyun Kim†, “Manifold-Constrained MPPI: Real-Time Sampling-Based Control for Nonlinear Equality-Constrained Robotic Systems,” International Journal of Control, Automation, and Systems, 2026.
손재락, 심재훈†, 김상현†, “유계 참조 보상과 조향률 제약을 통한 이중 조향 이동로봇의 정밀 도킹 성능 개선,” 제어·로봇·시스템학회 논문지, 2026.